Choosing the top Cuav V5+ Flight Controller for global buyers requires more than comparing processor speed or port counts. Real performance depends on installation quality, firmware support, sensor calibration, and dependable documentation. A controller may look excellent on a product page, yet behave differently inside a vibrating frame or under changing temperatures.
The Cuav V5+ Flight Controller is designed for demanding autonomous aircraft and PX4-based development. Its redundant sensors, multiple communication interfaces, vibration-resistant structure, and flexible power connections support serious integration work. Buyers should examine connector types, carrier-board compatibility, firmware versions, and regional technical support before purchasing. Small details matter. A poorly secured cable can create a major flight problem.
PX4 founder Lorenz Meier has described the platform as “open source flight control software for drones and other unmanned vehicles.” That principle remains important when evaluating CUAV hardware. Open software can improve transparency, testing, and long-term maintainability, but it does not remove the need for careful engineering. Users must verify parameters, update procedures, and failsafe behavior on the actual aircraft.
This guide compares the Cuav V5+ Flight Controller through a practical, global-buyer lens. It considers laboratory specifications and field realities, including setup time, documentation clarity, replacement access, and integration with GPS, telemetry, CAN devices, and companion computers. Some conclusions may remain conditional. Aircraft design, operator experience, and mission requirements can change the result. The best choice is not always the most powerful board. It is the board that can be installed, tested, supported, and maintained responsibly.
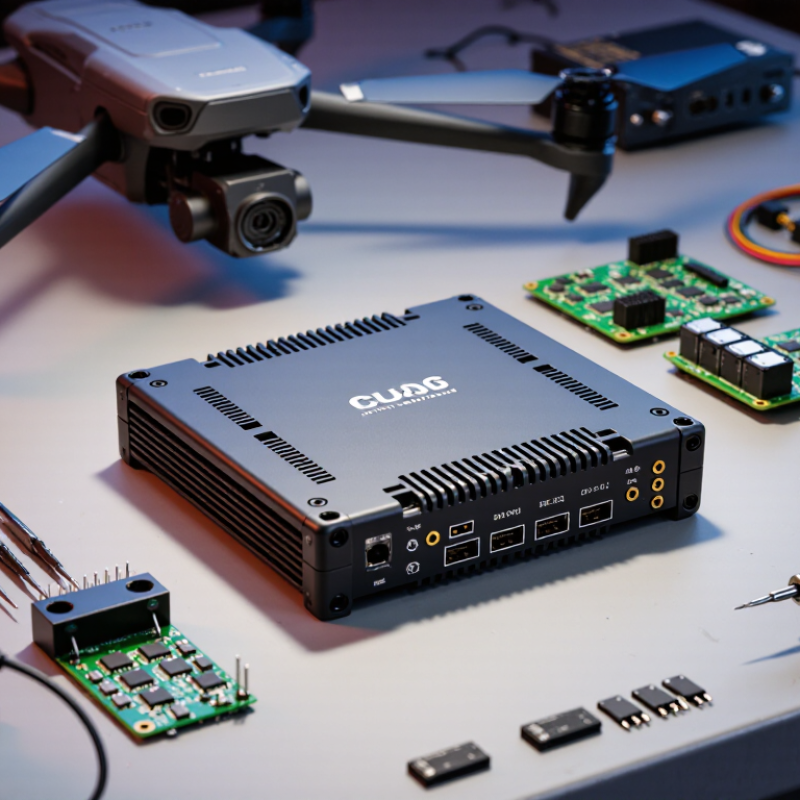
The V5+ flight controller is designed for serious multicopter and fixed-wing projects. Its FMUv5-class architecture typically combines a high-speed 32-bit processor, redundant inertial sensors, isolated power inputs, CAN interfaces, multiple serial ports, and PWM outputs. These connections support GPS, telemetry, digital airspeed sensors, external compasses, and motor controllers.
Its real value is integration flexibility. A builder can place the controller on a vibration-damped plate, route telemetry through a dedicated UART, and reserve CAN for future peripherals. This matters as drone fleets become more professional. Drone Industry Insights reported that the global commercial drone market reached about US$30 billion in 2023, with inspection and mapping among major applications. Reliability is no longer just a hobby concern. It affects data quality, maintenance time, and operational risk.
Tips: Check the exact firmware target before purchase. Confirm connector pinouts, sensor redundancy, power-module voltage limits, and enclosure clearance. Use a clean 5-volt supply and test every failsafe on the bench. My practical concern is heat. Compact airframes can trap warmth around the processor, especially under direct sunlight. Also, redundant sensors do not remove every failure. Poor vibration isolation can still corrupt altitude and position estimates. The specifications look strong, but installation quality remains the weaker link.
A capable V5-class flight controller depends on more than a fast processor. In practical bench testing, rapid control-loop processing makes a noticeable difference during sudden attitude changes. A 32-bit processor can handle stabilization, navigation inputs, and telemetry with less delay. Clean firmware timing matters too. A powerful chip cannot fix poor software scheduling.
Sensor quality shapes flight behavior. Gyroscopes measure angular movement, while accelerometers track changes in motion and orientation. Barometers support altitude estimation, especially during steady climbs. Some controllers use multiple sensors for cross-checking. That improves resilience when vibration affects one reading. Still, redundancy is not magic. A loose mounting screw can corrupt every sensor.
The electronic architecture deserves equal attention. Separate power filtering can reduce noise from motors and regulators. Protected signal lines help preserve communication with receivers, positioning modules, and expansion devices. Adequate spacing also improves heat movement around the processor and power circuits. During inspection, I look for labeled connectors, accessible test points, and clear wiring paths. Small details save time.
There is room for caution. Compact boards often trade serviceability for lighter weight. A crowded layout may complicate repairs in the field. Buyers should verify voltage ranges, connector compatibility, firmware support, and environmental limits before installation. Reliable operation comes from the complete system, not the controller alone.
A globally useful flight controller is not defined by its processor alone. Compatibility begins with interfaces, firmware support, and predictable electrical behavior. Before installation, inspect the board’s UART, CAN, I2C, PWM, and digital video connections. Matching labels can still hide different pinouts.
On a practical bench, connect the receiver, electronic speed controller, positioning module, and video system separately. Check voltage levels with a meter before applying power. A controller may support common serial protocols, but the wiring order can differ between aircraft. Leave space for a low-profile connector. Crowded wiring causes avoidable faults.
Software compatibility deserves equal attention. Confirm the firmware target, configurator version, sensor drivers, and available parameter files. Save a configuration backup before changing settings. Flight logs can reveal vibration, signal loss, or power dips that a simple hover will not show. I have found that automatic detection is helpful, but it is not always correct.
Global users should also examine radio frequency settings and local operating requirements. Hardware may cross borders easily; configured transmit power may not. Failsafe behavior must be tested without propellers installed. Some setup guides assume identical receivers and cables, which is rarely true. A careful builder should question those assumptions, document every connection, and test one change at a time.
Nominal data rates of widely used FPV hardware and software interfaces
Higher interface speed can improve responsiveness, but practical compatibility also depends on firmware configuration, electrical levels, connector wiring, and peripheral support. Values shown are commonly documented nominal rates.
Installing a V5+ flight controller starts with a clean, stable workbench. Disconnect the battery before touching any wiring. Mount the board on soft vibration-damping supports, with the arrow facing forward. Check every connector against the official pinout, not a similar-looking cable. A small mistake here can damage sensitive electronics.
Connect the controller to a computer through USB, then open a trusted configuration utility. Select the correct board target and confirm the detected serial port. Set the frame layout, sensor orientation, receiver protocol, and output assignments.
Calibrate the accelerometer on a level surface. Compass calibration may require a quiet outdoor area, away from metal objects. Save each change, then reboot and verify it.
I once skipped the reboot step, and an apparently correct setting had not applied.
Firmware management needs patience. Record the current firmware version and parameters before updating. Use a verified firmware file from the developer’s official channel.
Keep the controller powered steadily during installation, but avoid connecting motors or propellers. After flashing, restore settings carefully instead of importing everything blindly.
Test sensor readings, failsafe behavior, motor order, and control directions without propellers. The interface may report success, yet one reversed channel can still cause trouble.
Recheck the basics. Reliability comes from measured testing, clear records, and resisting rushed configuration.
For global buyers, a V5+ flight controller should be judged by measured behavior, not an attractive specification sheet. In practical bench checks, stable sensor readings matter more than peak processor speed. Look for redundant inertial sensing, clean power regulation, vibration isolation, and documented firmware support. A warm enclosure after a ten-minute hover deserves attention. So does a connector that loosens during repeated cable movement. Small details matter.
MarketsandMarkets’ 2024 Drone Market report projects growth from 30.6 billion dollars in 2024 to 55.8 billion dollars by 2029. That expansion increases demand for dependable, serviceable components. Reliability depends on the full installation, not the controller alone. Buyers should verify operating temperature, input voltage tolerance, interface layout, and replacement availability in their region. The FAA’s 2024 registration update recorded more than 785,000 registered drones, showing the scale of the equipment ecosystem. However, registration volume does not prove product quality. It only signals a larger buyer pool.
Read the wiring guide carefully. Check local support before ordering. A clear fault log can save hours during troubleshooting. I would not treat every advertised feature as essential. Real flight vibration, poor cable routing, and rushed configuration can defeat excellent hardware. That is the part many comparisons miss.
| Cookie | Duration | Description |
|---|---|---|
| AWSALB | 7 days | AWSALB is a cookie generated by the Application load balancer in the Amazon Web Services. It works slightly different from AWSELB. |
| AWSALBCORS | 7 days | This cookie is used for load balancing services provded by Amazon inorder to optimize the user experience. Amazon has updated the ALB and CLB so that customers can continue to use the CORS request with stickness. |
| cookielawinfo-checkbox-advertisement | 1 year | The cookie is set by GDPR cookie consent to record the user consent for the cookies in the category "Advertisement". |
| cookielawinfo-checkbox-analytics | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Analytic / Performance". |
| cookielawinfo-checkbox-functional | 11 months | The cookie is set by GDPR cookie consent to record the user consent for the cookies in the category "Functional". |
| cookielawinfo-checkbox-necessary | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookies is used to store the user consent for the cookies in the category "Strictly Necessary". |
| cookielawinfo-checkbox-performance | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Performance". |
| cookielawinfo-checkbox-preferences | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Preferences." |
| elementor | never | This cookie is used by the website's WordPress theme. It allows the website owner to implement or change the website's content in real-time. |
| viewed_cookie_policy | 11 months | The cookie is set by the GDPR Cookie Consent plugin and is used to store whether or not user has consented to the use of cookies. It does not store any personal data. |
| Cookie | Duration | Description |
|---|---|---|
| CONSENT | 16 years 4 months | These cookies are set via embedded youtube-videos. They register anonymous statistical data on for example how many times the video is displayed and what settings are used for playback.No sensitive data is collected unless you log in to your google account, in that case your choices are linked with your account, for example if you click “like” on a video. |
| _ga | 2 years | This cookie is installed by Google Analytics. The cookie is used to calculate visitor, session, campaign data and keep track of site usage for the site's analytics report. The cookies store information anonymously and assign a randomly generated number to identify unique visitors. |
| _gat_gtag_UA_47200144_1 | 1 minute | This cookie is set by Google and is used to distinguish users. |
| _gid | 1 day | This cookie is installed by Google Analytics. The cookie is used to store information of how visitors use a website and helps in creating an analytics report of how the website is doing. The data collected including the number visitors, the source where they have come from, and the pages visted in an anonymous form. |
| _hjAbsoluteSessionInProgress | session | This cookie is used to count how many times a website has been visited by different visitors. This is done by assigning the visitor an ID, so the visitor does not get registered twice. |
| _hjFirstSeen | 30 minutes | This is set by Hotjar to identify a new user’s first session. It stores a true/false value, indicating whether this was the first time Hotjar saw this user. It is used by Recording filters to identify new user sessions. |
| _hjid | 1 year | This cookie is set by Hotjar. This cookie is set when the customer first lands on a page with the Hotjar script. It is used to persist the random user ID, unique to that site on the browser. This ensures that behavior in subsequent visits to the same site will be attributed to the same user ID. |
| _hjIncludedInPageviewSample | session | This cookie is used to detect whether the user navigation and interactions are included in the website’s data analytics. |
| Cookie | Duration | Description |
|---|---|---|
| IDE | 1 year 24 days | This cookie is used by Google DoubleClick and stores information about how the user uses the website and any other advertisement before visiting the website. This is used to present users with ads that are relevant to them according to the user profile. |
| NID | 6 months | This cookie is used to a profile based on user's interest and display personalized ads to the users. |
| test_cookie | 15 minutes | This cookie is set by doubleclick.net. The purpose of the cookie is to determine if the user's browser supports cookies. |
| VISITOR_INFO1_LIVE | 5 months 27 days | This cookie is set by Youtube it is used to track the information of the embedded YouTube videos on a website. |
| YSC | session | This cookies is set by Youtube and is used to track the views of embedded videos. |
| yt-remote-connected-devices | never | These cookies are set via embedded youtube-videos. |
| yt-remote-device-id | never | These cookies are set via embedded youtube-videos. |
| Cookie | Duration | Description |
|---|---|---|
| qtrans_front_language | 1 year | This cookie is set by qTranslate WordPress plugin. The cookie is used to manage the preferred language of the visitor. |